What happened
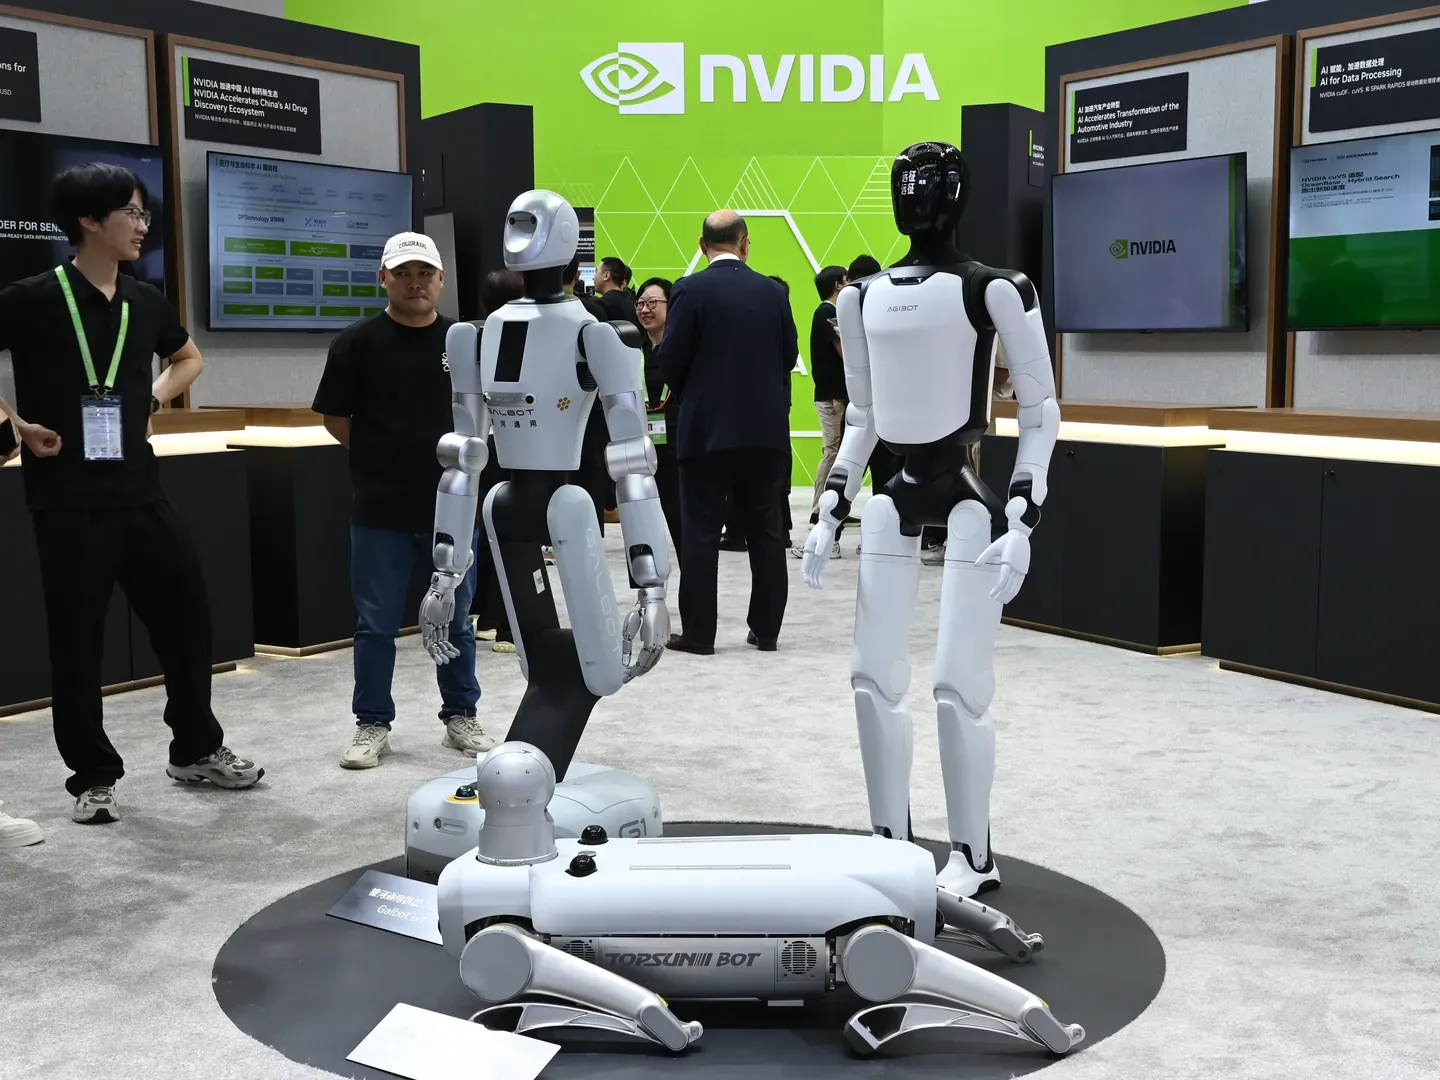
- NVIDIA released Isaac ROS 5.0 on September 22 during ROSCon 2026 in Toronto, according to the announcement on its corporate blog. It’s open-source software and is available on GitHub.
- The release packages setup and manipulation tasks as skills agents can invoke, among them fine-tuning FoundationStereo to adapt cameras and pick-and-place of parts as a standalone skill.
- It adds support for ROS Lyrical and Ubuntu 24.04, and contributes to ROS Lyrical an accelerated memory transport interface that doesn’t depend on a single vendor.
- NVIDIA says its FoundationPose inference library runs 5.5 times faster, and cites Ekumen with collision-free trajectory planning in 2 to 5 milliseconds.
Why it matters
- Turning calibration and manipulation into skills an agent invokes changes who can get a robot working. It stops requiring an integrator who writes the whole workflow and starts requiring someone who knows how to describe the task.
- For logistics and agro-industrial operations in Chile, Peru and Colombia, the cost of adapting a robotic cell to a new line was always higher than the cost of the robot. That’s the line item this announcement goes after, and it’s also the one no figure in the announcement measures.
- A consequence the announcement doesn’t mention: if the agent chooses which skill to run, tracing a failure stops being a code log and becomes a decision log. Nobody in the chain has that kind of log standardized today.
The number
1.3 million is the number of ROS developers NVIDIA says it’s targeting with this release.
Context
The bet on open ecosystems goes back further, to the purchase of Hugging Face, and at the same conference Alphabet’s robotics subsidiary released its own foundation under a permissive license. The debate over agent autonomy turned into operational risk now reaches the hardware that moves objects.
What’s next
- Isaac ROS 5.0 has been available since September 22 for Jetson platforms, from Orin Nano to Thor.
- No timelines announced for the next version or for expanding the skills catalog.
Bottom line
For years the argument against collaborative robots was that reprogramming them cost more than hiring someone. The argument still stands; what changed is how much it costs to reprogram them.
Sources
Edited by Rodrigo Cornejo. How we select, verify and correct each note.